| Welcome, Guest |
You have to register before you can post on our site.
|
| Online Users |
There are currently 30 online users.
» 1 Member(s) | 29 Guest(s)
Al Yard
|
| Latest Threads |
Shimming the rotor hub
Forum: Maintenance & Troubleshooting (162/A600)
Last Post: Homer Bell
3 hours ago
» Replies: 3
» Views: 82
|
162F for sale
Forum: Helicopters Marketplace
Last Post: Homer Bell
5 hours ago
» Replies: 7
» Views: 1,444
|
E36-8570 Talon Oil Temp S...
Forum: General Discussion
Last Post: Robin Scalzo
10-26-2026, 11:12 PM
» Replies: 0
» Views: 44
|
Fuel tank insulation
Forum: General Discussion
Last Post: Jared Hartzell
10-25-2026, 02:15 AM
» Replies: 6
» Views: 585
|
Pedals become stiff after...
Forum: Maintenance & Troubleshooting (162/A600)
Last Post: Homer Bell
10-23-2026, 12:22 PM
» Replies: 0
» Views: 70
|
tail rotor shaft drive in...
Forum: Modifications & Recommendations
Last Post: Graeme Smith
10-22-2026, 07:26 AM
» Replies: 33
» Views: 5,123
|
Grease Tool
Forum: General Discussion
Last Post: Lyle Swallows
10-22-2026, 04:54 AM
» Replies: 1
» Views: 120
|
I have a new rotorway MAI...
Forum: Helicopters Marketplace
Last Post: Homer Bell
10-19-2026, 12:24 AM
» Replies: 1
» Views: 219
|
162F spark plugs
Forum: General Discussion
Last Post: Lyle Swallows
10-01-2026, 02:46 AM
» Replies: 4
» Views: 790
|
The Digital Rotortach Sto...
Forum: Digilin LEDtechnics
Last Post: Lyle Swallows
09-27-2026, 07:58 PM
» Replies: 2
» Views: 290
|
|
|
| Pedals become stiff after 20 plus years of being free |
|
Posted by: Homer Bell - 10-23-2026, 12:22 PM - Forum: Maintenance & Troubleshooting (162/A600)
- No Replies
|
 |
Chris’s T. was at Jim’s last week and complained about his pedals becoming very stiff after being free for years. He disconnected things until he discovered it was in fact the pedal its self that was binding. I suggested he drill a small hole in the top of the pedal casting just deep enough to be able to get a little oil to get thru to the shaft. This is something I usually do on new builds so I can add lube later if needed.
He actually drilled more than one hole and added some light oil. This worked well and now we are happy to report pedal is now free.
|

|
|
| Shimming the rotor hub |
|
Posted by: Homer Bell - 10-23-2026, 12:11 PM - Forum: Maintenance & Troubleshooting (162/A600)
- Replies (3)
|
|
For the few who are needing to shim their hub plate to center the hub on the main shaft. This is something you will need to do at some point if you run your ship long enough. Peel ply shims are no longer available so coming up with the right combination of shims to get the desired friction and get the hub centered can be a challenge . You can buy shims stock at NAPA and others , but you may not be able to find the really thin stuff like .004. Here’s where you go to the trash can and dig out an old aluminum pop can, usually around .004. You can fold it over and cut a half moon circle out of it with a good pair of scissors to get you pin hole.
And BTW, that breakaway pressure can be quite a bit more than what the book saying and it will be fine. I’ve several times seen brand new assemblies come from the factory with pressures of 30# or more. So get it centered and don’t worry so much about that pressure. 20# would be just fine,
|
|
|
|
| The Digital Rotortach Story. Part 1/3. CONCEPTION |
|
Posted by: Jon Davis - 09-25-2026, 06:01 PM - Forum: Digilin LEDtechnics
- Replies (2)
|
 |
Hi all,
It was actually Graeme Smith from Australia that started this whole story back in the late 90’s, and much of the credit should go to his foresight.
I had been an ardent RC model helicopter enthusiast for several years and read a series of articles in a RC helicopter magazine by ventriloquist Jeff Dunham about building a Rotorway kit. I was totally hooked.
I purchased a Rotorway EXEC 90 kit in 1994, one of the first in Australia. A few years later Graeme was appointed as the new Australian distributor (not sure of the date but must have been around 1996), and as many of you would know, Graeme has for many decades been involved in experimental classification helicopters and has researched and implemented many new innovations and upgrades, particularly with the RotorWay helicopters.
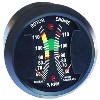
Westach produce some great cost effective gauges for experimental and amateur built aircraft and a lot of their gauges were supplied in the RW kits. , However their analog rotortach always had some noticeable shortcomings, such has poor needle tracking, poor RPM accuracy, the need for calibration before use, drift with temperature, and it was often affected when the radio transmit button was pressed. As an person that grew up and learnt electronics in the 60’s and 70’s analog era I would be the first to admit that analog circuitry is not an ideal or easy solution for this type of application that demands high repeatable accuracy and negligible affect from environmental conditions. But digital solutions were less readily available in the 80’s and 90’s .
The original Westberg tacho is a pure analog device and as such is obviously very susceptible to RF interference. Whilst shielded cables and using correct grounding techniques can sometimes help alleviate these problems, a digital tacho has a very much higher level of immunity to this problem. A slight amount of RF induced onto the signal cables, or directly radiated through the plastic tacho case (only a few millivolts of interference) onto the PCB is likely to affect the reading of an analog tacho. With a digital device, a small amount of superimposed RF signal will have no effect until its amplitude comes close to the amplitude of the digital signal (about 3 - 4 volts, ie. a thousand times higher)
Also the gauge readings would vary with temperature. Owners may experiences temp changes from -40 to +100F. Whilst in Australia we don't experience temperature changes of that magnitude, and the digital tacho there is (by definition) no drift with temperature on a digital device. Temperature drift is an "analog thing" and can only occur in analog circuits. A digital tacho is all digital except where it interfaces to the meter movement where the digital signal is converted back to analog. ie 98% of the device is digital. The analog components that are used to drive the meter operate at unity gain and hence will have negligible temperature drift.
A digital tacho is also inherently very precise (using mathematical algorithms) and hence capable of very accurate tracking of rotor and engine speed.
Knowing that I owned an electronics design and manufacturing company ( mainly working at that time in the industrial and oil/coal exploration fields), and was also a RotorWay owner, around 1998 he approached me to see if I was interested in designing a new improved rotortach that would overcome the shortfalls in the existing unit.
We decided that the best option would be for us to develop completely new circuitry based on digital microprocessor electronics to replace the original analog circuit board, but retain the existing case and meter movements etc. That way we could offer cost effective upgrades to anyone with an existing rotortach, by simply replacing the circuit board, and without the need and high costs involved in a total product redesign and associated plastic injection moldings for new case components etc.
In 1999, we had a successful prototype PCB working. Even though we could design a microcontroller digital circuit with optically isolate engine and rotor signal inputs with crystal controlled RPM accuracy that would never require customer calibration (eliminating the need for the optical rotor blade RPM measuring tool that was supplied with the RW kit) we did come a bit unstuck with the meter movements - as you will soon see.
For the original prototype unit we carefully “characterised” / calibrated the engine and rotor meters such that we knew the exact relationship of meter voltage to RPM reading on the dial. And this relationship in the form of a digital look-up table was programed in to the code that went in to the microcontroller. So, all good, and the result was perfect. Absolute accuracy and precise tracking of engine and rotor display over the full range – just what we were after.
However, the meter movements themselves are inherently analog devices and as such every individual meter movement is just slightly different in its sensitivity. We hadn’t actually considered that at the time (silly us!).
So, when we assembled our second prototype for testing, with another set of new meter movements, the result was disappointing as the meter readings were both slightly out in accuracy, and they did not track perfectly.
What this meant was that every tacho we were to manufacture would clearly require it’s own individual custom calibration look up table that would need to be downloaded in to the firmware when it was manufactured. At the time that was certainly not good news. Every tacho manufactured would need to be unique and custom programmed to suit it's particular meter movements – and that hasn’t changed to this date. Hence the important serial number on the back of every tacho, and this relates back to its own manufacturing file with it’s unique calibration data. For every tacho that has been manufactured since 1999, we keep all it’s details on file in case we ever need to refer to it for repairs etc.
However fortunately we found a way to simplify this onerous task and speed up the measuring and calibrating of every individual meter movement. We developed a separate program (using MATLAB) that could interpolate and generate a full look up table covering the 45% to 114% dial range based on twelve spot measurements. It still takes time to do each one but the end result is perfect accuracy and tracking of both needles.
And that is how we came to start modifying and upgrading RW rotortachs with an effective digital solution.
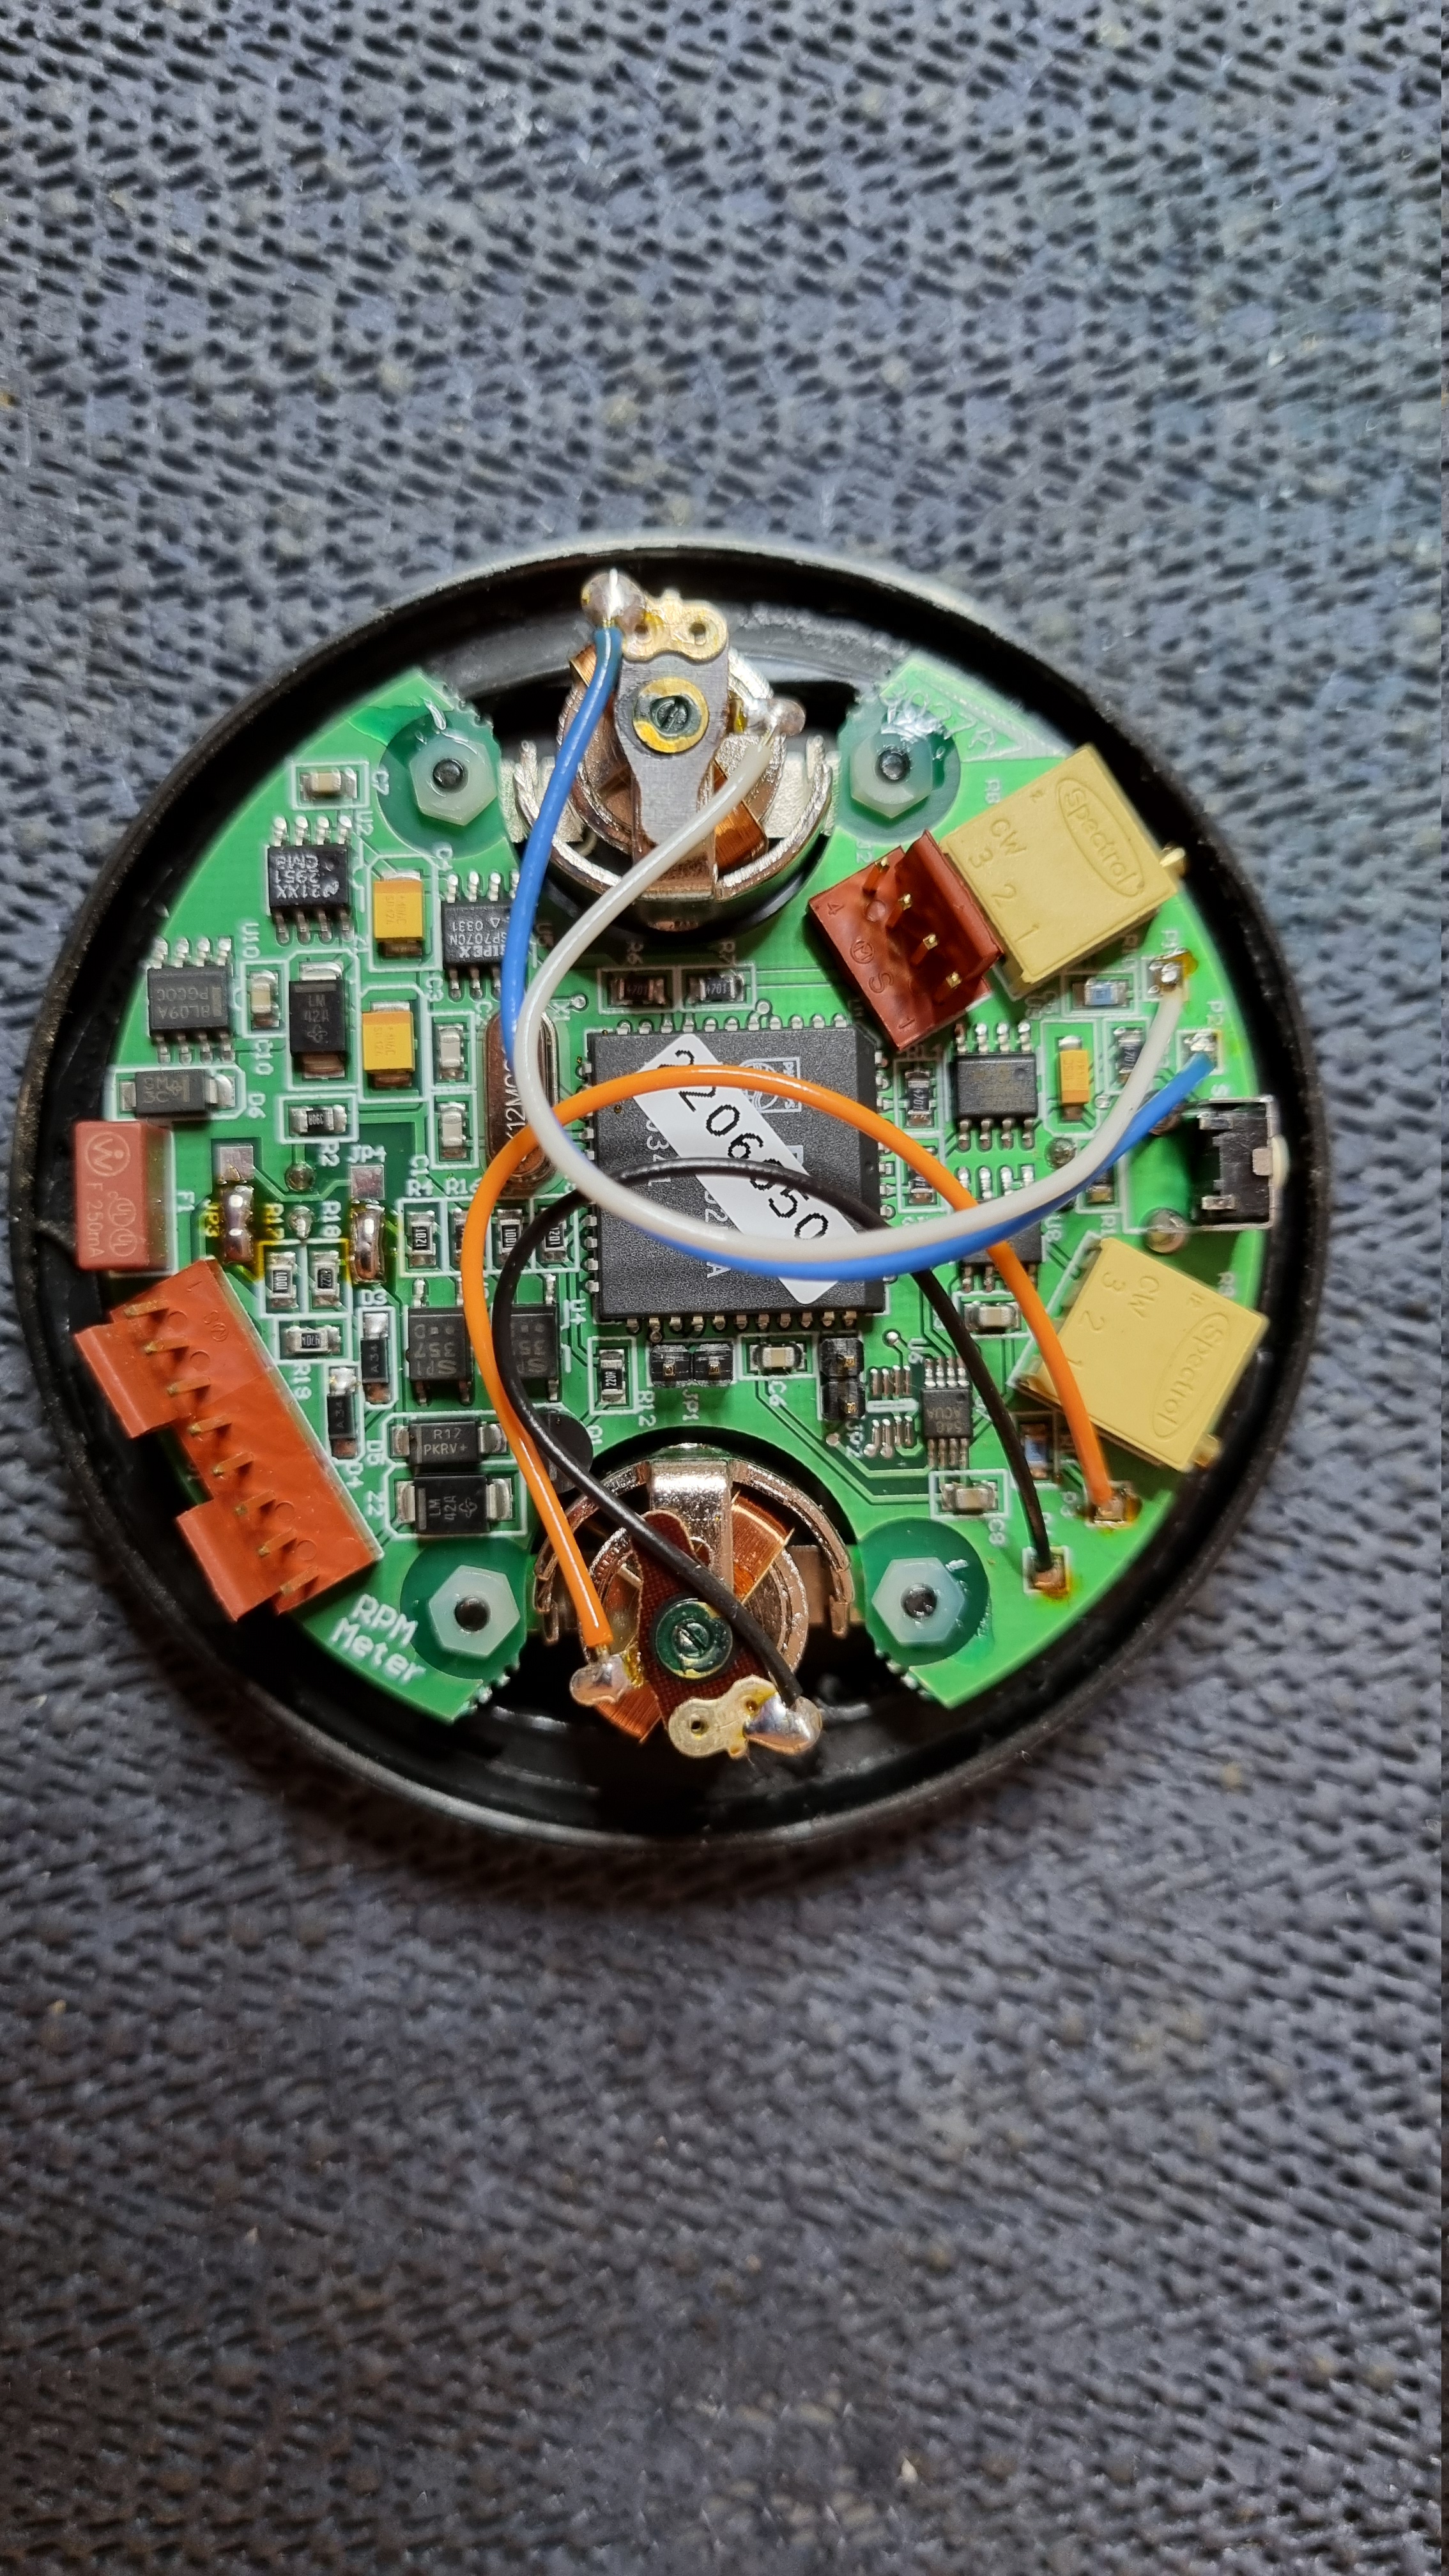
Sadly I do not have a photo of the original digital circuit board. But soon after releasing the new digital RW upgrade we got approached by Russ Gerrish around 2002 who had heard about our rotortach and was after one to suit the Jet Exec. And that started a whole new interesting chain of developments of the product that continues to this day. That will all be covered in my Part 2 of the story. Attached is a photo of the revised circuit from 2002 that was resigned to suit both the standard RW and also the Jet Exec. That’s 24 years ago! I just can’t believe where all the years have gone.
|
|
|
|
| Tail boom support for transport |
|
Posted by: Homer Bell - 09-18-2026, 01:27 PM - Forum: General Discussion
- No Replies
|
|
The question comes up many times about how to support the tail during trailering. Something I’ve used now for many years with decent success for probably 100,000 miles is a band you can get at a welding supply store that is used to hold tanks for welding gas. An 8” band comes with a handy standoff bracket that can be helpful to attach your support tube. With a towel wrapped around the boom just in front of the vertical stabilizer, this can give you a good place to support the tail near the rear, where it should be supported, not anywhere forward of there.
If your trailer is too short and the tail hangs over, you can bolt a 2x8 to the floor and hang it out the back to give you a place to hook your support. I used a 16’ trailer for many years using this setup. Trailers shorter than that should probably be avoided, but some have used 12,14’ with a long tongue and pulled backward. Always remember, if you pull backward, you must secure your doors with a cord or rope around them to keep from blowing open. If doors come open they can break your windscreen as well as the door. Wail a minute forget that, I sell both of those things. Windscreens are now over 2K and doors are over $500. Plus shipping is usually several hundred, not including crating.
It’s best to use tandem axle trailers with lightly sprung suspension and a ridge frame with little or no end to end flex. Snow mobile trailers are not good . I have used them, but we made a truss along both side with a cable which firmed it up a bunch.
Almost every gathering someone pulls in with a damaged tail boom, don’t let that be you.
|
|
|
|
|